For information on the latest version, please have a look at 1.33.5.
6.6.2 minimal_rt_monitoring_sample.cpp
This example (2_minimal_rt_monitoring_sample.cpp) shows a minimal realtime
monitoring setup using the DRFLEx API:
open the realtime (RT) monitoring channel with
connect_rt_control(),configure the RT session with
set_rt_control_input(),register an RT monitoring callback (
set_on_rt_monitoring_data),and start/stop RT monitoring with simple console input.
Caution
Realtime monitoring and control are supported only on a real robot system. The sample sets IP_ADDRESS to 127.0.0.1; set it to the IP address of the real controller (for example 192.168.137.100) before running it.
This example is located in the following path:
API-DRFL/example/Linux_64/2_minimal_rt_monitoring_sample.cpp
See the example on the Doosan Robotics API-DRFL GitHub.
Overview & Global Configuration
The sample starts by selecting the DRCF protocol version and creating a global DRFLEx instance.
The sample defines DRCF_VERSION as 2 on its first line. Edit that line to match the controller, or delete it and pass -DDRCF_VERSION=2 or -DDRCF_VERSION=3 to the compiler; while the line is present, it overrides the compiler option.
#define DRCF_VERSION 2 // Set 2 or 3 according to drcf version.

#include "../../include/DRFLEx.h"

#include <cstring>
#include <iostream>
#include <thread>

using namespace DRAFramework;
// ...
const std::string IP_ADDRESS = "127.0.0.1";
CDRFLEx robot; // Instance for APIs

bool get_control_access = false; // Variable to check control authority
bool is_standby = false; // Variable to check whether the robot state is standby.

#define GREEN  "\033[1;32m"
#define CYAN   "\033[1;36m"
DRCF_VERSION: must match the controller firmware (e.g. 2 or 3).IP_ADDRESS: set to127.0.0.1in the sample. Replace it with the IP address of the real controller.Color macros (
GREEN,CYAN) are used to print colored output in the terminal.
Realtime Connection Setup
The main function first opens the realtime monitoring connection.
int main(){
    // Connect to the drcf cotnroller.
    bool ret = robot.connect_rt_control(IP_ADDRESS);
    std::cout << "open connection return value " << ret << std::endl;
    if (true != ret) {
        std::cout << "Cannot open connection to robot @ " << IP_ADDRESS
                        << std::endl;
        return 1;
    }
    // For rt - monitoring, we don't need to have "Getting control access".
    // however, for rt-writing like servoj_rt, we still need to have "control access" and "state standby".
connect_rt_control(IP_ADDRESS)opens the UDP realtime channel to the controller.If the connection fails (e.g. wrong IP, no real controller), the program prints an error and exits.
RT monitoring only (read-only) does not require control authority.
RT writing (e.g.
servoj_rt, torque commands) does not require control authority either, but the robot must be in STATE_STANDBY or STATE_MOVING. The comment in the sample that says RT writing needs control access is outdated.
RT Monitoring Callback
The example registers a lambda callback to receive realtime state data.
robot.set_on_rt_monitoring_data([](LPRT_OUTPUT_DATA_LIST data)->void{
    if (!data) return;
    auto ms = std::chrono::duration_cast<std::chrono::milliseconds>(std::chrono::system_clock::now().time_since_epoch()).count();
    printf(GREEN "[%.3f] === Robot State ===\n", ms / 1000.0);
    printf(CYAN "Joint Position: ");
    for (int i = 0; i < 6; ++i) {
        printf("%.3f%s", data->actual_joint_position[i], (i < 5) ? ", " : "\n");
    }
    printf(CYAN "Joint Velocity: ");
    for (int i = 0; i < 6; ++i) {
        printf("%.3f%s", data->actual_joint_velocity[i], (i < 5) ? ", " : "\n");
    }
    printf(CYAN "Joint Torque: ");
    for (int i = 0; i < 6; ++i) {
        printf("%.3f%s", data->actual_joint_torque[i], (i < 5) ? ", " : "\n");
    }
    printf(CYAN "Gravity Torque: ");
    for (int i = 0; i < 6; ++i) {
        printf("%.3f%s", data->gravity_torque[i], (i < 5) ? ", " : "\n");
    }
    // Pretty matrix printer
    auto print_matrix = [](const char* name, float mat[6][6]) {
        printf(CYAN "%s:\n", name);
        for (int i = 0; i < 6; ++i) {
            printf(CYAN "  [");
            for (int j = 0; j < 6; ++j) {
                printf(CYAN "%7.3f%s", mat[i][j], (j < 5) ? ", " : "");
            }
            printf(CYAN "]\n");
        }
    };
    print_matrix(CYAN "Jacobian Matrix", data->jacobian_matrix);
    print_matrix(CYAN "Mass Matrix", data->mass_matrix);
    print_matrix(CYAN "Coriolis Matrix", data->coriolis_matrix);

});
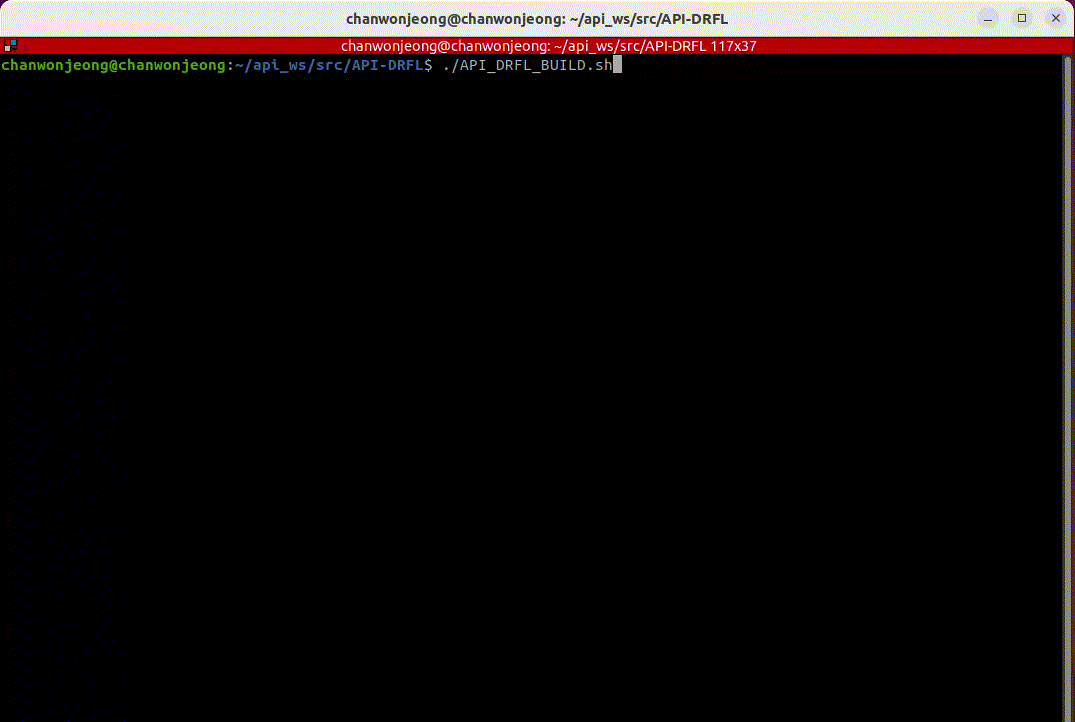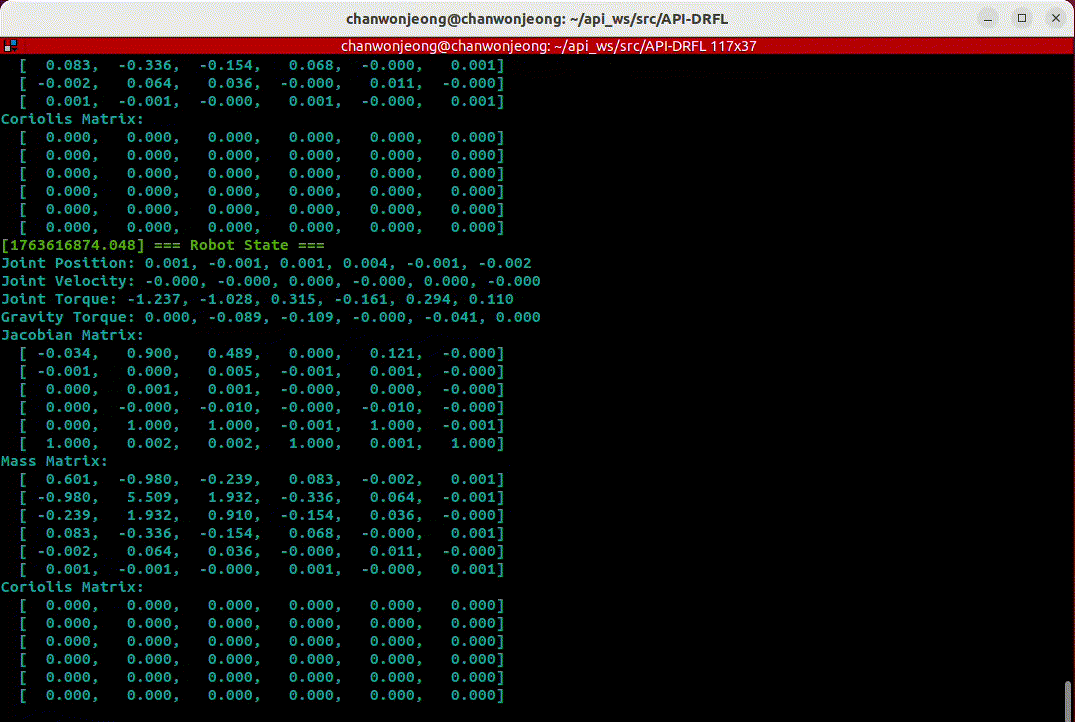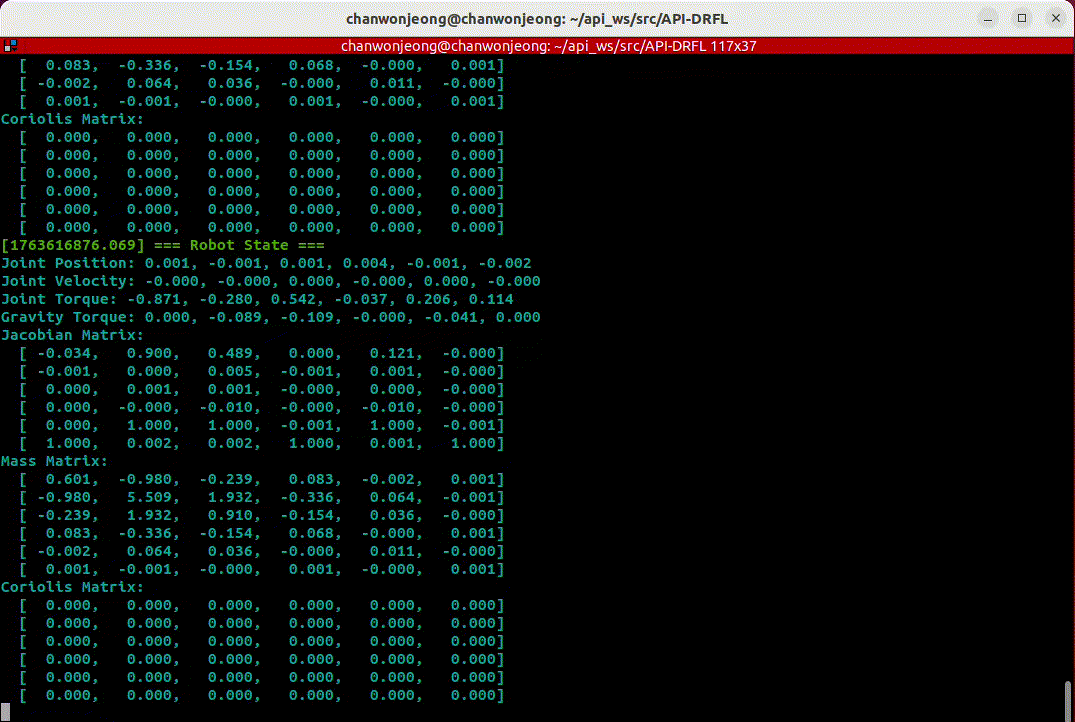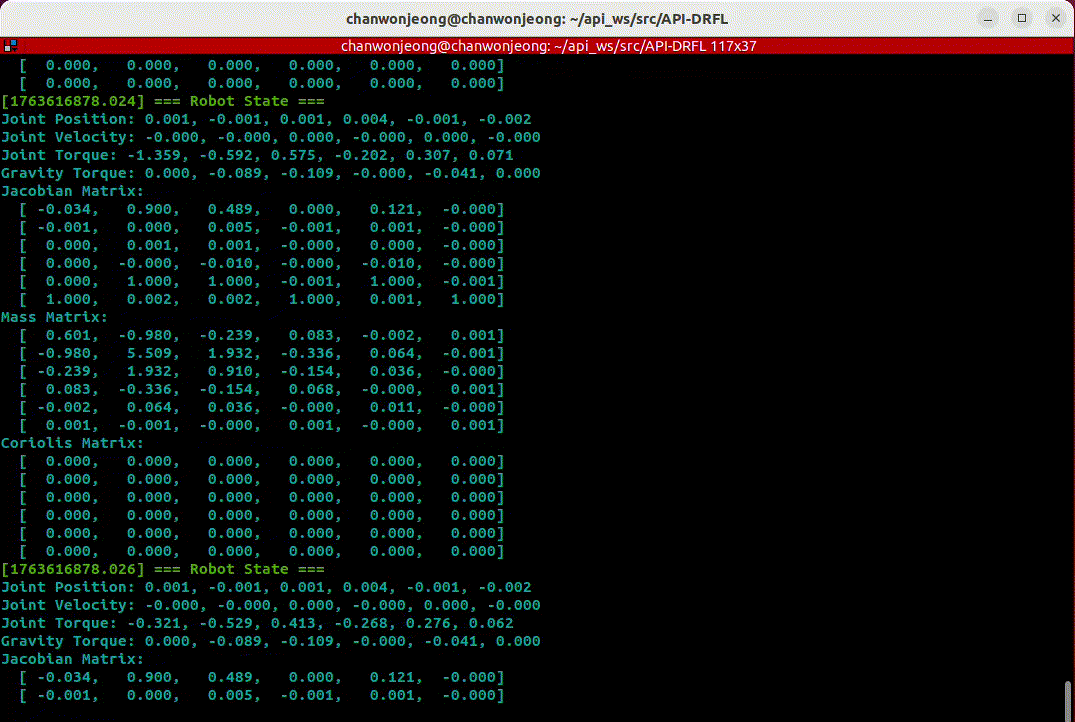
The callback returns immediately when data is null. Otherwise it prints a timestamp based on the local system clock, joint positions, joint velocities, joint torques, gravity torques, and dynamic matrices (Jacobian, Mass, Coriolis).
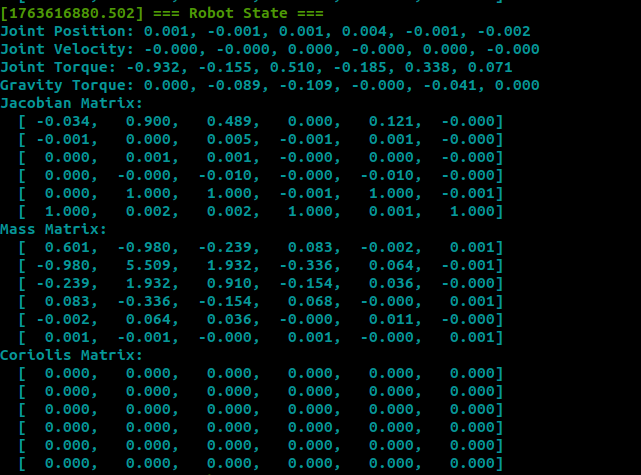
RT Session Configuration & Start
After registering the callback, the sample configures the RT session with set_rt_control_input(), waits for Enter, calls start_rt_control(), waits for Enter again and calls disconnect_rt_control().
string version = "v1.0";
// float period = 0.002;
float hz = 100.0f;
int losscount = 4;
std::cout << "RT Result " << robot.set_rt_control_input(version, hz, losscount) << std::endl;

std::cout << "Press Enter to continue..." ;
std::cin.get();  // Waits for user to press Enter
robot.start_rt_control();

std::cout << "Press Enter to terminate..." ;
std::cin.get();  // Waits for user to press Enter
robot.disconnect_rt_control();
return 0;
RT Output
Before starting the RT session, the program calls set_rt_control_input().
string version = "v1.0";
// float period = 0.002;
float hz = 100.0f;
int losscount = 4;
std::cout << "RT Result " << robot.set_rt_control_input(version, hz, losscount) << std::endl;
version = "v1.0": selects the RT protocol version.hz = 100.0f: passed as thefPeriodargument, the communication period in seconds.losscount = 4: passed as thenLossCntargument, the allowed consecutive loss count.
See set_rt_control_input for the parameters. The return value is printed to the console. It reports only that the configuration was sent, not that the controller accepted it.
Start & Stop RT Monitoring
The example uses simple Enter key prompts to start and stop RT monitoring.
std::cout << "Press Enter to continue..." ;
std::cin.get();  // Waits for user to press Enter
robot.start_rt_control();

std::cout << "Press Enter to terminate..." ;
std::cin.get();  // Waits for user to press Enter
robot.disconnect_rt_control();
return 0;
After the first
Enter, the sample callsstart_rt_control().After the second
Enter,disconnect_rt_control()closes the realtime monitoring channel and the program exits.