For information on the latest version, please have a look at 1.33.5.
movec (Auto Mode)
This function moves the robot along an arc in the task space, to the target position via a waypoint or to a specified angle from the current position. Available with DRCF_VERSION 2 and 3. The eOrientation and eAppType parameters exist only with DRCF_VERSION 2.
Definition
DRFLEx.h within class CDRFLEx, public section
bool movec(float fTargetPos[2][NUM_TASK],
           float fTargetVel[2],
           float fTargetAcc[2],
           float fTargetTime = 0.f,
           MOVE_MODE eMoveMode = MOVE_MODE_ABSOLUTE,
           MOVE_REFERENCE eMoveReference = MOVE_REFERENCE_BASE,
           float fTargetAngle1 = 0.f,
           float fTargetAngle2 = 0.f,
           float fBlendingRadius = 0.f,
           BLENDING_SPEED_TYPE eBlendingType = BLENDING_SPEED_TYPE_DUPLICATE,
           MOVE_ORIENTATION eOrientation = DR_MV_ORI_TEACH,
           DR_MV_APP eAppType = DR_MV_APP_NONE) {
    return _movec_ex(_rbtCtrl, fTargetPos, fTargetVel, fTargetAcc, fTargetTime,
                     eMoveMode, eMoveReference, fTargetAngle1, fTargetAngle2,
                     fBlendingRadius, eBlendingType, eOrientation, eAppType);
};
Parameter
Parameter Name |
Data Type |
Default Value |
Description |
|---|---|---|---|
fTargetPos[0] |
float[6] |
Waypoint [mm, deg] |
|
fTargetPos[1] |
float[6] |
Target location [mm, deg] |
|
fTargetVel |
float[2] |
Linear Velocity, Angular Velocity [mm/s, deg/s] |
|
fTargetAcc |
float[2] |
Linear Acceleration, Angular Acceleration [mm/s2, deg/s2] |
|
fTargetTime |
float |
0.0 |
Reach Time [sec] |
eMoveMode |
|
Refer to the Definition of Constant and Enumeration Type |
|
eMoveReference |
|
Refer to the Definition of Constant and Enumeration Type |
|
fTargetAngle1 |
float |
0.0 |
angle1 |
fTargetAngle2 |
float |
0.0 |
angle2 |
fBlendingRadius |
float |
0.0 |
Radius for blending [mm] |
eBlendingType |
|
Refer to the Definition of Constant and Enumeration Type |
|
eOrientation |
|
Orientation control option of the tool |
|
eAppType |
|
Application hint for motion (if supported by controller) |
Note
If a value is passed to
fTargetVel(e.g.,{30, 0}), the input corresponds to the linear velocity of the motion, while the angular velocity is determined proportionally to the linear velocity.If a value is passed to
fTargetAcc(e.g.,{60, 0}), the input corresponds to the linear acceleration of the motion, while the angular acceleration is determined proportionally to the linear acceleration.If
fTargetTimeis specified, values are processed based onfTargetTime, ignoringfTargetVelandfTargetAcc.If the
eMoveModeisMOVE_MODE_RELATIVE,fTargetPos[0]andfTargetPos[1]are defined in the relative coordinate system of the previous position. (fTargetPos[0]is the relative coordinate from the starting point, whilefTargetPos[1]is the relative coordinate fromfTargetPos[0].)If
fTargetAngle1is greater than 0 andfTargetAngle2is equal to 0,fTargetAngle1is applied as the total rotated angle on the circular path.When both
fTargetAngle1andfTargetAngle2are greater than 0,fTargetAngle1refers to the total rotating angle moving at a constant velocity on the circular path, whilefTargetAngle2refers to the rotating angle in the rotating section for acceleration and deceleration. In that case, the total angle moved along the circular path isfTargetAngle1 + 2 × fTargetAngle2.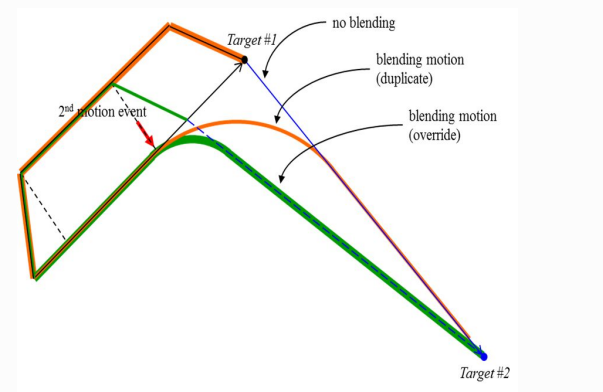
Caution
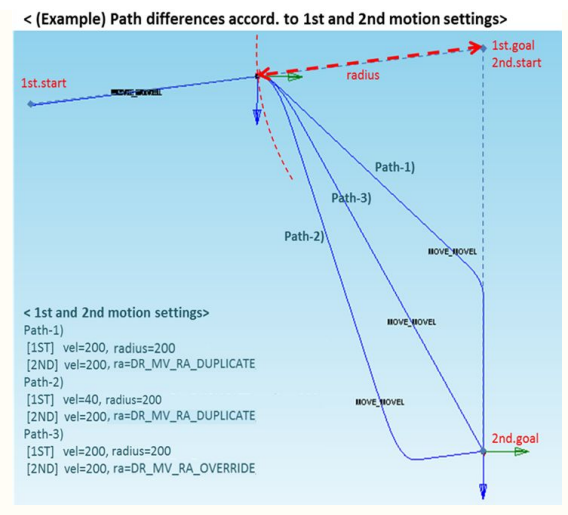
If the following motion is blended with eBlendingType set to BLENDING_SPEED_TYPE_DUPLICATE and fBlendingRadius > 0, the preceding motion can terminate after the following motion when the remaining motion time (determined by the remaining distance, velocity, and acceleration of the preceding motion) is greater than the motion time of the following motion. Refer to the following image for more information.
Return
Value |
Description |
|---|---|
0 |
Error |
1 |
Success |
Note
Returns false without a message when the robot is in STATE_EMERGENCY_STOP, STATE_SAFE_OFF, STATE_SAFE_OFF2, STATE_SAFE_STOP or STATE_SAFE_STOP2.
Example
// CASE 1
float x1[2][6] = { {559,434.5,651.5,0,180,0}, {559,434.5,251.5,0,180,0} };
float tvel[2] = {50, 50}; // Set the task velocity to 50 (mm/sec, deg/sec).
float tacc[2] = {100, 100}; // Set the task acceleration to 100 (mm/sec2, deg/sec2).
drfl.movec(x1, tvel, tacc);
// Moves to x1[1] with a velocity of 50 and acceleration of 100 via x1[0] along the arc trajectory.

// CASE 2
float x1r[2][6] = { {559,434.5,651.5,0,180,0}, {559,434.5,251.5,0,180,0} };
float ttime = 5.f;
float zero[2] = {0.f, 0.f};
drfl.movec(x1r, zero, zero, ttime);
// Moves along the arc trajectory to x1r[1] via x1r[0] with a reach time of 5 seconds.

// CASE 3
float x1b[2][6] = { {559,434.5,651.5,0,180,0}, {559,434.5,251.5,0,180,0} };
float x2b[2][6] = { {559,234.5,651.5,0,180,0}, {559,234.5,451.5,0,180,0} };
float tvelb[2] = {50, 50};
float taccb[2] = {100, 100};
float blending_radius = 50;
drfl.movec(x1b, tvelb, taccb, 0, MOVE_MODE_ABSOLUTE, MOVE_REFERENCE_BASE, 0, 0, blending_radius);
drfl.movec(x2b, tvelb, taccb, 0, MOVE_MODE_ABSOLUTE, MOVE_REFERENCE_BASE, 0, 0, 0, BLENDING_SPEED_TYPE_DUPLICATE);
// Two consecutive arc segments are executed; the first uses a 50 mm blend radius, the second uses DUPLICATE blending.
These examples show arc motion via a waypoint, time-based arc motion, and consecutive arcs with blending.
Use fBlendingRadius and eBlendingType to control how adjacent arc segments are connected smoothly.