1.4 Realtime External Control
Real-time External Control is a UDP/IP-based communication API for users who want to directly control the robot arm from an external PC through the Doosan controller.
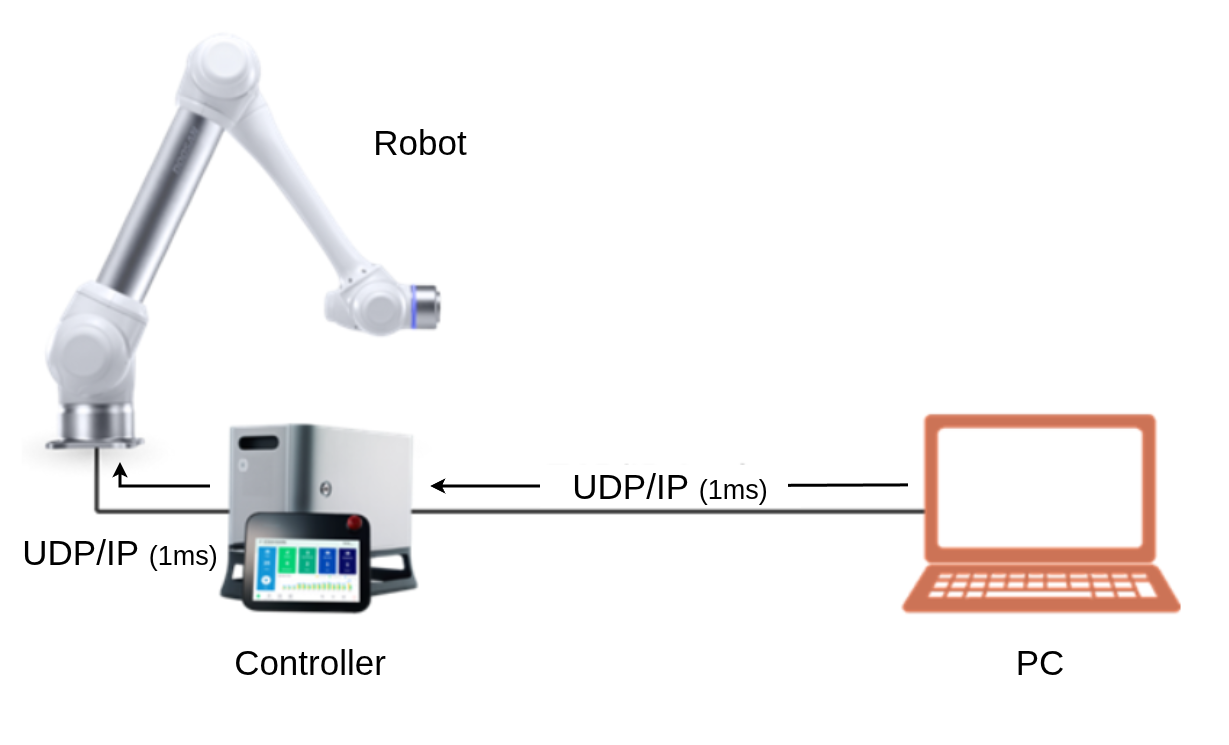
Realtime UDP Communication
It operates independently of the existing TCP/IP-based communication API. At a set period of up to 1 kHz, it sends and receives the input data (external controller → robot controller) and output data (robot controller → external controller) required for real-time control, and you can also send servo control commands (servoj_rt, servol_rt, speedj_rt, speedl_rt, torque_rt) separately.
Note
While the RT channel supports high-speed communication up to 1 kHz, the standard TCP/IP API operates at a slower cycle. Monitoring data on the TCP/IP channel is sent at 10 Hz on DRCF v2 and on DRCF v3 before 3.5, and at 50 Hz on DRCF 3.5 or later.