3.1 Common
Common functions can be called in Manual or Auto mode, with these exceptions. Manual mode only: set_tool, add_tool, del_tool, set_tcp, add_tcp, del_tcp, set_tool_shape, overwrite_user_cart_coord. Auto mode only: set_state_led_color, set_state_led_off, state_led_reset, get_state_led_rule, drl_start, drl_resume, change_operation_speed, system_shut_down.
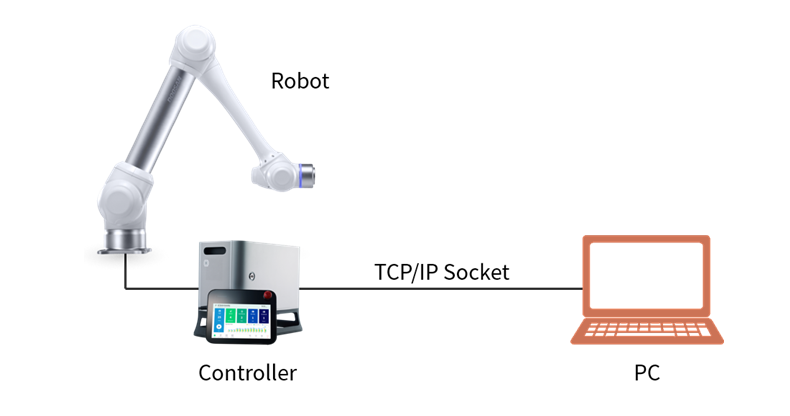
Source by DoosanRobotics Training/OnlineCourses
These functions include system connection, mode/state monitoring, program execution utilities, motion execution interfaces, robot kinematics, I/O control, tool/TCP configuration, safety state monitoring, and various controller-level services.
- 3.1.1 Connection
- 3.1.2 Mode/State
- 3.1.3 Monitoring/Callbacks
- 3.1.4 Program/DRL_Execution
- 3.1.5 Motion execution
- 3.1.6 Position
- 3.1.7 Kinematics/Math
- 3.1.8 Velocity
- 3.1.9 Force/Compliance
- 3.1.10 Tool
- 3.1.11 Tcp
- 3.1.12 Payload
- 3.1.13 Coordinate
- 3.1.14 I/O
- 3.1.15 Modbus
- 3.1.16 Serial(Flange)
- 3.1.17 TP
- 3.1.18 Report alarm
- 3.1.19 LED
- 3.1.20 Safety(Configuration parameter)
- 3.1.21 Safety(State/Mode)
- 3.1.22 Servo Power
- 3.1.23 Hold to Run (H2R)