movesx (Auto Mode)
This function moves the robot along a spline curve that connects the current position to the target position (the last waypoint) through the waypoints in the task space. The input velocity/acceleration means the maximum velocity/acceleration in the path. If eVelOpt is SPLINE_VELOCITY_OPTION_CONST, the robot moves at the input velocity at constant speed. If constant speed is not possible for the given waypoints and velocity, the robot moves at variable speed (SPLINE_VELOCITY_OPTION_DEFAULT).
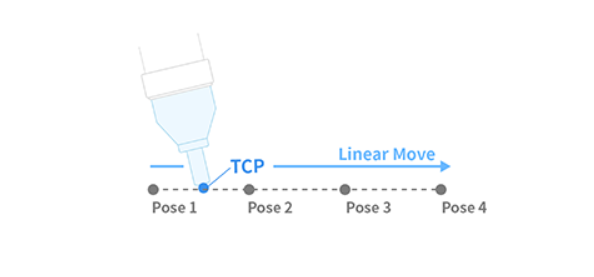
Definition
DRFLEx.h within class CDRFLEx, public section
bool movesx(float fTargetPos[MAX_SPLINE_POINT][NUM_TASK],
            unsigned char nPosCount,
            float fTargetVel[2],
            float fTargetAcc[2],
            float fTargetTime = 0.f,
            MOVE_MODE eMoveMode = MOVE_MODE_ABSOLUTE,
            MOVE_REFERENCE eMoveReference = MOVE_REFERENCE_BASE,
            SPLINE_VELOCITY_OPTION eVelOpt = SPLINE_VELOCITY_OPTION_DEFAULT)
{
    return _movesx(_rbtCtrl, fTargetPos, nPosCount, fTargetVel, fTargetAcc,
                   fTargetTime, eMoveMode, eMoveReference, eVelOpt);
};
Parameter
Parameter Name |
Data Type |
Default Value |
Description |
|---|---|---|---|
fTargetPos |
float [MAX_SPLINE_POINT][6] |
Maximum 100 waypoint information [mm, deg] |
|
nPosCount |
unsigned char |
Number of valid waypoints. nPosCount must be 1 to 100. |
|
fTargetVel |
float[2] |
Linear Velocity, Angular Velocity [mm/s, deg/s] |
|
fTargetAcc |
float[2] |
Linear Acceleration, Angular Acceleration [mm/s2, deg/s2] |
|
fTargetTime |
float |
0.f |
Reach Time [sec] |
eMoveMode |
|
Refer to the Definition of Enumeration Type |
|
eMoveReference |
|
Refer to the Definition of Enumeration Type |
|
eVelOpt |
|
Refer to the Definition of Enumeration Type |
Note
If a value is passed to fTargetVel (e.g.,
fTargetVel ={30, 0}), the input corresponds to the linear velocity of the motion, while the angular velocity is determined proportionally to the linear velocity.If a value is passed to fTargetAcc (e.g.,
fTargetAcc ={60, 0}), the input corresponds to the linear acceleration of the motion, while the angular acceleration is determined proportionally to the linear acceleration.If fTargetTime is specified, values are processed based on fTargetTime, ignoring fTargetVel and fTargetAcc.
When eMoveMode is
MOVE_MODE_RELATIVE, each pos in the position list is defined as a relative coordinate with respect to the preceding pos. (If position list=[q1, q2, …,q(n-1), q(n)], q1 is relative to the starting point, while q(n) is relative to q(n-1).)This function does not support online blending of previous and subsequent motions.
Caution
If the SPLINE_VELOCITY_OPTION_CONST option (constant-velocity option) is selected for eVelOpt but the distance and velocity between the input waypoints do not allow it, the constant-velocity motion cannot be used, and the motion automatically switches to the variable-velocity motion (eVelOpt = SPLINE_VELOCITY_OPTION_DEFAULT).
Return
Value |
Description |
|---|---|
0 |
Error |
1 |
Success |
Note
Returns false without a message when the robot is in STATE_EMERGENCY_STOP, STATE_SAFE_OFF, STATE_SAFE_OFF2, STATE_SAFE_STOP or STATE_SAFE_STOP2.
Example
// CASE 1 : Moves absolute coordinate standard (mode = MOVE_MODE_ABSOLUTE)
float xpos[4][6];
unsigned char xposNum = 4;
float tvel[2] = { 50, 100 };
float tacc[2] = { 50, 100 };

xpos[0][0]=559; xpos[0][1]=434.5; xpos[0][2]=651.5;
xpos[0][3]=0;   xpos[0][4]=180;  xpos[0][5]=0;

xpos[1][0]=559; xpos[1][1]=434.5; xpos[1][2]=251.5;
xpos[1][3]=0;   xpos[1][4]=180;  xpos[1][5]=0;

xpos[2][0]=559; xpos[2][1]=234.5; xpos[2][2]=251.5;
xpos[2][3]=0;   xpos[2][4]=180;  xpos[2][5]=0;

xpos[3][0]=559; xpos[3][1]=234.5; xpos[3][2]=451.5;
xpos[3][3]=0;   xpos[3][4]=180;  xpos[3][5]=0;

drfl.movesx(xpos, xposNum, tvel, tacc, 0, MOVE_MODE_ABSOLUTE);
// Moves the spline curve that connects the waypoints defined in xpos
// with a maximum linear/angular velocity of 50 and maximum acceleration of 100.

// CASE 2 : Moves relative coordinate standard (mode = MOVE_MODE_RELATIVE)
float xpos2[4][6];
xpos2[0][0]=0;   xpos2[0][1]=+400; xpos2[0][2]=0;
xpos2[0][3]=0;   xpos2[0][4]=0;    xpos2[0][5]=0;   // from start position -> x0

xpos2[1][0]=0;   xpos2[1][1]=0;   xpos2[1][2]=+400;
xpos2[1][3]=0;   xpos2[1][4]=0;   xpos2[1][5]=0;   // from x0 -> x1

xpos2[2][0]=0;   xpos2[2][1]=+200; xpos2[2][2]=0;
xpos2[2][3]=0;   xpos2[2][4]=0;    xpos2[2][5]=0;   // from x1 -> x2

xpos2[3][0]=0;   xpos2[3][1]=0;    xpos2[3][2]=+200;
xpos2[3][3]=0;   xpos2[3][4]=0;    xpos2[3][5]=0;   // from x2 -> x3

drfl.movesx(xpos2, xposNum, tvel, tacc, 0, MOVE_MODE_RELATIVE);
// Moves the spline curve that connects the relative waypoints in xpos2
// with max velocity 50 (mm/sec, deg/sec) and max acceleration 100 (mm/sec2, deg/sec2).